Introduction
High-speed manufacturing has become increasingly important for plastic packaging companies that produce large quantities of containers, cups, lids, and tubs. Customers expect consistent packaging quality, while manufacturers need to control labor, material waste, and production time. A high-speed IML robot can help address these requirements by automating the placement of printed labels during the injection molding process.
In-Mold Labeling, commonly known as IML, combines labeling and plastic molding into one coordinated operation. The robot places a label inside an open mold, and the injection molding machine forms the plastic product around it. The finished package leaves the molding process with its label already integrated into the surface.
The success of a high-speed IML system depends on more than rapid robot movement. Machine compatibility, mold design, label handling, and precise cycle synchronization are all essential.
How High-Speed IML Technology Works
A high-speed IML robot follows a programmed sequence that coordinates label feeding, label placement, product removal, and machine movement.
The process starts when the robot collects labels from a magazine. Specialized gripping tools hold the labels securely during movement. The robot then enters the open mold and positions each label against the designated surface.
After releasing the labels and clearing the mold area, the robot allows the injection molding machine to continue its cycle. Molten plastic enters the mold, takes the required shape, and bonds with the label under suitable processing conditions.
Once the molded product has cooled sufficiently, the finished container is removed. Depending on the system, this operation may be coordinated with the placement of new labels to reduce unnecessary waiting.
The precise sequence varies according to the mold, machine, product, and automation design. Manufacturers should validate the entire sequence under realistic production conditions.
Why Production Cycle Time Matters
Cycle time determines how long the equipment takes to complete a production cycle. Even a small improvement can become significant when a machine operates continuously over long production periods.
For example, a manufacturer producing thousands of containers daily may lose substantial output when the robot repeatedly waits for labels, travels farther than necessary, or receives delayed signals from the injection molding machine.
A high-speed IML robot can help reduce handling time by using optimized movement paths and coordinated operations. However, the total cycle is also affected by plastic filling, cooling, mold opening, mold closing, and product ejection.
If cooling is the limiting stage, increasing robot speed alone may not improve overall output. The correct approach is to measure each stage and identify the actual bottleneck.
Side-Entry and Top-Entry Configurations
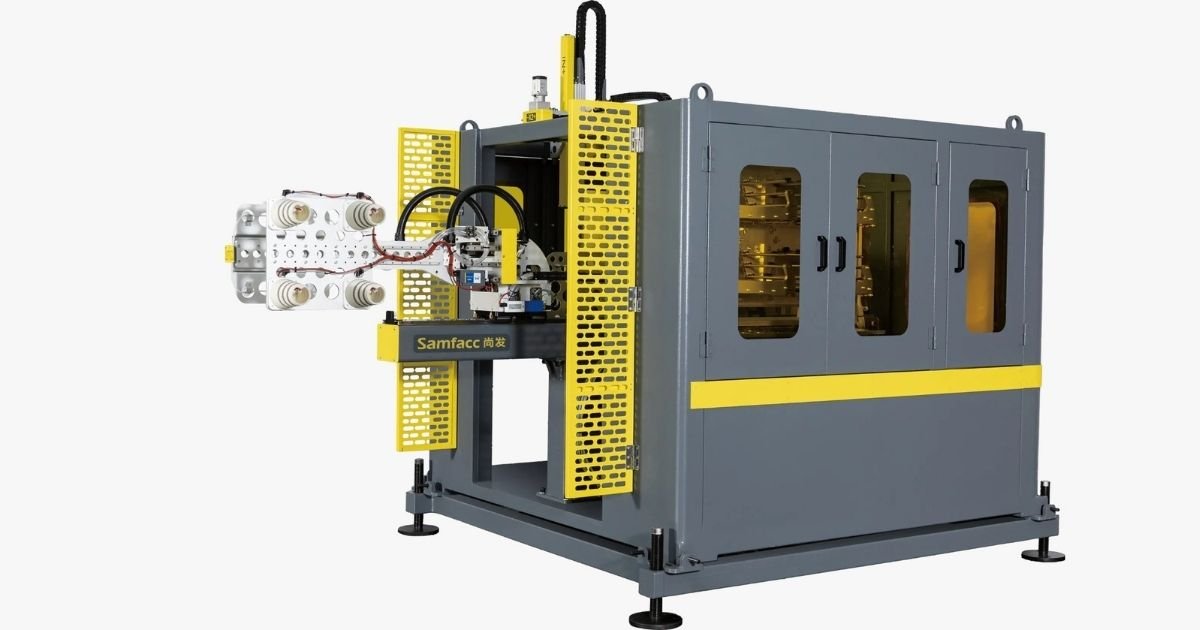
High-speed IML robots are available in different configurations, including side-entry and top-entry designs.
Side-entry systems access the mold from the side and can be suitable for certain high-volume packaging applications, including thin-wall cups and tubs. Their suitability depends on the mold layout, available clearance, and required movement.
Top-entry systems approach the mold from above and may be appropriate for selected containers, buckets, lids, and applications that benefit from vertical access.
Neither design is universally better. Manufacturers should consider mold dimensions, cavity spacing, machine layout, robot reach, product weight, and the required production cycle before selecting a configuration.
Label Handling at High Speed
Reliable label handling is essential for fast production. Labels must be separated from the stack, transferred without distortion, and placed accurately into their intended positions.
Problems can arise when labels stick together, curl, carry excessive static, or differ in size. A label that shifts during robot movement may produce a visible defect even when the robot reaches its programmed coordinates.
The label magazine, separation method, gripping tool, and placement surface should therefore be designed around the actual label material and dimensions.
Manufacturers should also test how the labels behave under normal factory conditions. Changes in temperature, humidity, storage practices, or label material can influence handling performance.
Consistent label supply helps prevent the robot from waiting for missing or incorrectly presented labels.
Integrating the Robot With the Injection Molding Machine
An IML robot and injection molding machine must communicate through a coordinated control sequence. The robot needs reliable information about mold position, machine readiness, permitted movement, and fault conditions.
Poor integration can create unnecessary waiting, interrupted cycles, or unsafe movement. For example, a robot may complete its task quickly but still wait because the machine has not reached the required position.
Integration planning should include mechanical clearance, communication signals, safety interlocks, and the timing of label insertion and product removal.
The mold itself also requires attention. Cavity spacing, label retention, cooling, and ejection must support the intended robot movements. If these elements are planned separately, the completed production line may fail to achieve the expected performance.
A coordinated project involving the machine, mold, robot, and auxiliary equipment is generally a more reliable approach.
Measuring Productivity and Efficiency
Manufacturers should assess high-speed IML performance using measurable production indicators rather than relying only on advertised speed.
Useful indicators include total cycle time, good units produced per hour, rejected products, label-related stoppages, equipment availability, and changeover duration.
Production data should distinguish between theoretical capacity and actual output. A machine may have a fast nominal cycle but produce fewer saleable units because of maintenance stops, material issues, label defects, or downstream congestion.
It is also important to check quality across every mold cavity. A system that produces high volumes with inconsistent label placement may increase inspection costs and material waste.
Comparing performance before and after installation helps determine whether the automation has achieved its intended objectives.
Maintenance for Continuous Operation
High-speed equipment requires a structured maintenance plan. Frequent inspections can help identify worn gripping components, loose connections, sensor problems, damaged cables, and issues with the label magazine.
Vacuum systems should be checked for leaks when vacuum gripping is used. Sensors and control components should be tested according to the manufacturer’s recommendations.
Operators should be trained to recognize abnormal movement, repeated missed labels, and unusual stopping patterns. Recording these events provides useful information for maintenance teams.
Preventive maintenance should take place at appropriate intervals and follow established safety procedures. Guards and interlocks must remain functional, and hazardous maintenance work should only be performed by authorized personnel.
How to Select a High-Speed IML Robot
Before choosing equipment, define the required production volume, container design, label specifications, cavity count, and available machine details.
Request information about the robot’s compatible machine range, movement capacity, tooling options, control interface, changeover procedure, and service support. Ask the supplier to explain how the proposed system will achieve the target cycle with the intended mold and label.
A production trial is especially useful. It allows the buyer to assess label placement, product quality, cycle stability, and handling performance before final acceptance.
Conclusion
A high-speed IML robot can help packaging manufacturers improve handling efficiency and maintain consistent labeling at high production volumes. Its performance depends on coordinated equipment, reliable label feeding, appropriate mold design, and accurate machine communication.
By studying the complete production cycle and testing the system with actual materials, manufacturers can make more informed investment decisions and build a production line designed for dependable long-term operation.
Frequently Asked Questions
What affects IML robot speed?
Robot travel, label pickup, mold access, machine signals, product removal, and downstream handling all influence performance.
Is a high-speed IML robot suitable for every factory?
No. The equipment must match the product, mold, injection molding machine, production volume, and available factory space.
How can manufacturers improve IML cycle time?
They can measure the complete cycle, remove unnecessary waiting, improve integration, and address the stage that limits overall output.
Disclaimer: This article is for general informational purposes only and does not constitute professional, technical, or safety advice. IML robot specifications, cycle times, mold compatibility, label handling requirements, and integration needs vary by manufacturer, model, product, and production line, and may change without notice. High-speed automation equipment involves moving parts, injection molding hazards, and control-system safety requirements; installation, operation, and maintenance must follow the manufacturer’s safety documentation and applicable workplace safety standards. Readers should verify all technical details, safety interlocks, and integration requirements directly with the equipment supplier and qualified engineers before purchasing or commissioning any system. Any mention of specific configurations or components does not imply endorsement. The author and publisher disclaim any liability for decisions made based on this content.
Design a career you’re excited about—our career growth strategies help you navigate every stage with purpose.